Saturday, 16 April 2022

The GHZ Experiment

A GHZ gate
Consider a coin that can represent the behaviour of a quantum particle. This quantum coin [1] can be placed into an equal superposition of heads and tails, which is represented in Dirac (Ket) notation as follows:
\[(1) \hspace{5 mm}|\psi\rangle = \frac{1}{\sqrt2}(|H\rangle + |T\rangle)\]
\(|\psi\rangle\) (read: psi) represents the state of the quantum coin. \(|H\rangle\) represents the head component and \(|T\rangle\) represents the tails component. 1/√2 is the probability amplitude for each component of the superposition. Squaring this number gives the probability that a particular component will be the result when measured. That is, there is a (1/√2)2 = 0.5 (or 50%) probability that heads will be measured. Similarly, in this case, for tails.

Quantum coins can also be entangled. The following state, which represents two entangled quantum coins, is called a Bell state (see also the quantum circuit):
\[(2) \hspace{5 mm}|\psi\rangle = \frac{1}{\sqrt2}(|HT\rangle - |TH\rangle)\]
When the coins are entangled, they are not in independent superpositions, but in a collective superposition. Which is to say, if one of the coins is measured as heads then the other coin, when measured, will be tails.

Quantum coins can be measured from any angle (and are still measured as only heads or tails - there are no 'side of coin' measurements, so-to-speak). To rotate the state in equation (2) from the default z-axis onto the x-axis, a Hadamard gate is applied to each coin (note: a Hadamard gate is conventionally symbolized as \(\boldsymbol H\), not to be confused with the ket \(|H\rangle\) representing heads in this post) . The Hadamard gate rotates the \(|H\rangle\) component to \(\frac{1}{\sqrt2}(|H\rangle + |T\rangle)\) and the \(|T\rangle\) component to \(\frac{1}{\sqrt2}(|H\rangle - |T\rangle)\).[2] This results in the following state (excluding the \(\frac{1}{\sqrt2}\)):

\[\begin{aligned}\boldsymbol{(H }&\boldsymbol{\otimes H)}(|HT\rangle - |TH\rangle) \\ &= (|H\rangle + |T\rangle)(|H\rangle - |T\rangle) - ((|H\rangle - |T\rangle)(|H\rangle + |T\rangle) \\ &= |HH\rangle - |HT\rangle + |TH\rangle - |TT\rangle - (|HH\rangle + |HT\rangle - |TH\rangle - |TT\rangle) \\ &= |HH\rangle - |HT\rangle + |TH\rangle - |TT\rangle - |HH\rangle - |HT\rangle + |TH\rangle + |TT\rangle \\ &= -(|HT\rangle - |TH\rangle)\end{aligned}\]

This is the same Bell state as in equation (2) except that a global phase (the minus sign, which is equivalent to π radians, or a 180° rotation around the axis origin) has been added. This global phase makes no difference to the calculated probabilities. A similar result occurs if the state is rotated onto the y-axis, or onto any arbitrary axis. In other words, that Bell state (called the singlet state) is rotationally invariant, ignoring the global phase which has no physical meaning. The rotation onto the y-axis uses the Phase gate (conventionally symbolized as \(\boldsymbol S\)) and Hadamard gate (conventionally symbolized as \(\boldsymbol H\), as noted above) to rotate the \(|H\rangle\) component to \(\frac{1}{\sqrt2}(|H\rangle + |T\rangle)\) and the \(|T\rangle\) component to \(\frac{i}{\sqrt2}(|H\rangle - |T\rangle)\).[3] This results in the following state (excluding the \(\frac{1}{\sqrt2}\)):

\[\begin{aligned}\boldsymbol{(H }&\boldsymbol{\otimes H)(S \otimes S)}(|HT\rangle-|TH\rangle) \\ &= (|H\rangle + |T\rangle)(i|H\rangle - i|T\rangle) - ((i|H\rangle - i|T\rangle)(|H\rangle + |T\rangle) \\ &= i|HH\rangle - i|HT\rangle + i|TH\rangle + -i|TT\rangle - (i|HH\rangle + i|HT\rangle + -i|TH\rangle + -i|TT\rangle) \\ &= i|HH\rangle - i|HT\rangle + i|TH\rangle + -i|TT\rangle - i|HH\rangle - i|HT\rangle + i|TH\rangle + i|TT\rangle \\ &= -i(|HT\rangle - |TH\rangle)\end{aligned}\]

Again, this is the same Bell state as in equation (2) except that a global phase (the imaginary −i, which is equivalent to 3*π/2 radians, or a 270° rotation around the axis origin) has been added.

Now how does the entanglement work? For example, if Alice and Bob take one of two quantum coins entangled as per equation (2) to distant locations, and measure their coin on a predetermined axis (say, the y-axis), how do they end up being measured in opposite orientations? This is the question that the EPR paradox raises. Einstein's answer was that there must be hidden "elements of reality" corresponding to the coin's orientation on any given axis. I discuss Bell's Theorem which demonstrates the constraints on that position - namely, that hidden variables can't be used to explain the measurements without also violating locality (i.e., cause/effect not greater than the speed of light). In this post, I want to outline an intuitive demonstration of those constraints via the GHZ experiment.

To begin, a three qubit entangled state is created, termed the GHZ state, as follows:

Figure 1: The GHZ state
In terms of our quantum coins, this can be represented as:
\[(3) \hspace{5 mm}|\psi\rangle = \frac{1}{\sqrt2}(|HHH\rangle + |TTT\rangle)\]
If Alice, Bob and Charlie each take one of the three quantum coins, measure it, and then compare results, they will find that they have all measured heads, or have all have measured tails.


Figure 2: xxx basis
Now suppose that Alice, Bob and Charlie instead rotate their respective coins onto the x-axis.[4] The resulting state is:

\(\begin{aligned}(4) \hspace{5 mm}|\psi\rangle = \frac{1}{2}(&|HHH\rangle + |HTT\rangle + \\ & |THT\rangle + |TTH\rangle)\end{aligned}\)

If we assign heads the value of 1 and tails the value of -1 then, for each component, the product of the three coin measurements will be 1. For example, \(|HTT\rangle\) gives 1 * -1 * -1 = 1. Similarly for the other components. This is a mathematical representation of the fact that for each of the four measurement possibilities, there will be an odd number of heads measured (1 or 3) and an even number of tails measured (0 or 2).

Figure 3: yyx basis
Now suppose that only Alice rotates her coin onto the x-axis, and instead Bob and Charlie rotate their coins onto the y-axis.[5] The resulting state is:

\(\begin{aligned}(5) \hspace{5 mm}|\psi\rangle = \frac{1}{2}(&|HHT\rangle + |HTH\rangle + \\ & |THH\rangle + |TTT\rangle)\end{aligned}\)

In this case, if we assign heads the value of 1 and tails the value of -1 then, for each component, the product of the three coin measurements will be -1. For example, \(|HHT\rangle\) gives 1 * 1 * -1 = -1. Similarly for the other components. This is a mathematical representation of the fact that for each of the four measurement possibilities, there will be an even number of heads measured (0 or 2) and an odd number of tails measured (1 or 3). Note that this is the opposite of the possible outcomes for state (4).

Symmetrically, if it is only Bob or Charlie, rather than Alice that rotates their coin onto the x-axis, while the others instead rotate their coins onto the y-axis, the resulting state is the same as equation (5). We can now list the product equations for each of the quantum states:

\((6) \hspace{5 mm}Alice_x * Bob_x * Charlie_x = 1 \hspace{5 mm}[from (4)]\)
\((7) \hspace{5 mm}Alice_x * Bob_y * Charlie_y = -1 \hspace{5 mm}[from (5)]\)
\((8) \hspace{5 mm}Alice_y * Bob_x * Charlie_y = -1 \hspace{5 mm}[from (5)]\)
\((9) \hspace{5 mm}Alice_y * Bob_y * Charlie_x = -1 \hspace{5 mm}[from (5)]\)

Now the product of the left-sides of the above equations is:

\(\begin{aligned}LHS = & Alice_x * Bob_x * Charlie_x * \\ & Alice_x * Bob_y * Charlie_y * \\ & Alice_y * Bob_x * Charlie_y * \\ & Alice_y * Bob_y * Charlie_x\end{aligned}\)

As each element appears twice, the equation can be rearranged as:

\(LHS = {Alice_x}^2 * {Bob_x}^2 * {Charlie_x}^2 * {Alice_y}^2 * {Bob_y}^2 * {Charlie_y}^2\)

Since LHS is the product of squares, LHS = 1. But the product of the RHS is:

\(RHS = 1 * -1 * -1 * -1 = -1\)

Thus the equations can't be jointly satisfied. This proves that there can't be hidden elements of reality (i.e., unknown predefined values) for each possible measurement combination since that would lead to contradiction. That is, quantum mechanics experimentally rules out local hidden variable theories.[6]

--

[1] Our quantum coin is a qubit, where \(|0\rangle\) and \(|1\rangle\) have been replaced by \(|H\rangle\) and \(|T\rangle\).

[2] See the Bloch Sphere in Figure 5 of this earlier blog post to visualize the equivalent qubit rotation.

[3] Derivation for the matrix product of \(\boldsymbol H\) and \(\boldsymbol S\):
\[\hspace{10 mm}\boldsymbol{HS} = \begin{bmatrix} 1 & 1 \\ 1 & −1 \end{bmatrix}\begin{bmatrix} 1 & 0 \\ 0 & i \end{bmatrix} = \begin{bmatrix} 1*1 + 0*1 & 0*1 + i*1 \\ 1*1 + 0*−1 & 0*1 + i*−1 \end{bmatrix} = \begin{bmatrix} 1 & i \\ 1 & −i \end{bmatrix}\]

[4] Derivation for Alice, Bob, and Charles rotating their coins from the z-axis onto the x-axis (excluding the \(\frac{1}{\sqrt2}\)):
\[\begin{aligned}\boldsymbol{(H }&\boldsymbol{\otimes H \otimes H)}(|HHH\rangle + |TTT\rangle) \\ & = (|H\rangle + |T\rangle)(|H\rangle + |T\rangle))(|H\rangle + |T\rangle) + ((|H\rangle - |T\rangle)(|H\rangle - |T\rangle)(|H\rangle - |T\rangle)) \\ & = |HHH\rangle + |HHT\rangle + |HTH\rangle + |HTT\rangle + |THH\rangle + |THT\rangle + |TTH\rangle + |TTT\rangle + \\ & \hspace{5 mm} |HHH\rangle - |HHT\rangle - |HTH\rangle + |HTT\rangle - |THH\rangle + |THT\rangle + |TTH\rangle - |TTT\rangle \\ & = |HHH\rangle + |HTT\rangle + |THT\rangle + |TTH\rangle\end{aligned}\]

[5] Derivation for Alice, Bob, and Charles rotating their coins from the z-axis onto the y-axis, y-axis, and x-axis respectively (excluding the \(\frac{1}{\sqrt2}\)):
\[\begin{aligned}\boldsymbol{(H }&\boldsymbol{\otimes H \otimes H)(S \otimes S\otimes I)}(|HHH\rangle + |TTT\rangle) \\ & = (|H\rangle + |T\rangle)(|H\rangle + |T\rangle))(|H\rangle + |T\rangle) + \\ & \hspace{5 mm} ((i|H\rangle + -i|T\rangle)(i|H\rangle + -i|T\rangle)(|H\rangle - |T\rangle)) \\ & = |HHH\rangle + |HHT\rangle + |HTH\rangle + |HTT\rangle + \\ & \hspace{5 mm}|THH\rangle + |THT\rangle + |TTH\rangle + |TTT\rangle + \\ & \hspace{5 mm} ii|HHH\rangle + -ii|HHT\rangle + -ii|HTH\rangle + --ii|HTT\rangle + \\ & \hspace{5 mm} -ii|THH\rangle + --ii|THT\rangle + --ii|TTH\rangle + ---ii|TTT\rangle \\ & = |HHH\rangle + |HHT\rangle + |HTH\rangle + |HTT\rangle + \\ & \hspace{5 mm} |THH\rangle + |THT\rangle + |TTH\rangle + |TTT\rangle + \\ & \hspace{5 mm} -|HHH\rangle + |HHT\rangle + |HTH\rangle + -|HTT\rangle + \\ & \hspace{5 mm} |THH\rangle + -|THT\rangle + -|TTH\rangle + |TTT\rangle \\ & = |HHT\rangle + |HTH\rangle + |THH\rangle + |TTT\rangle\end{aligned}\]

[6] Note that quantum mechanics rules out predefined measurement values for non-local hidden variable theories as well. However, if a theory is non-local then, once a measurement has been made for one coin, non-local variables can potentially be updated instantaneously thus potentially affecting subsequent measurements of the other coins.

Thursday, 10 February 2022

The Delayed-Choice Quantum Eraser

Figure 1: The delayed-choice quantum eraser experiment

Suppose a series of photons are sent through a double-slit apparatus. As you may know, an interference pattern is formed on the back screen. Each photon's trajectory can be represented as a wave that passes through both slits and is finally absorbed at a particular position on the back screen (with a specific probability).

Adding a splitting crystal (BBO in Figure 1) immediately after the slits converts the photon into two entangled photons, each with half the energy of the original photon. One photon (called the signal photon) goes to the back screen (D0) which, after a series of such experiments, builds up a blob pattern that does not exhibit interference. Why not? Because the wave function depends on the location where the photon pairs were created (as represented by the green line apex at the upper slit or the red line apex at the lower slit) and thus on which slit the original photon went through. This constitutes "which-way" information which destroys interference.

So far so good. Now suppose the second photon (called the idler photon) is sent on a long journey - a much longer journey than the signal photon took to get to the back screen - and then, optionally, a beam splitter is placed in its path. This is the delayed-choice aspect of the experiment.

If the beam splitter is present (as in Figure 1), then the idler photon hits one side of the beam splitter according to which slit the original photon went through (i.e., the red path comes from the lower slit and hits the lower side of the beam splitter, the green path comes from the upper slit and hits the upper side of the beam splitter). Analogous to the double-slit interaction, this beam splitter interaction can be represented as a wave that is reflected by and also passes through the beam splitter. Subsequently detecting the photon on the lower side of the beam splitter (D1) or the upper side (D2) will tell you nothing about which side of the beam splitter the idler photon came from, and thus nothing about which slit the original photon went through. That is, the "which-way" information has been lost. This is the eraser aspect of the experiment.

Given that the "which-way" information is erased when the beam splitter is present, what kind of pattern do you predict will be seen on the back screen (i.e., by the signal photons at D0)?

To see the answer, go back to the second paragraph of this post. What pattern was exhibited on the back screen then? A blob pattern that did not exhibit interference, and the same answer remains true here. The rest of the setup with the idler photon makes no difference at all. There is no mysterious "backwards-in-time" effect that changes the pattern (as is sometimes suggested), since the pattern is the same regardless of what subsequently occurred elsewhere.

Figure 2: D0 = D1 + D2 (with the beam splitter)

Now that is not quite the end of the story. It is possible to match up the idler photon detected at one of the final detectors (D1 or D2) with its entangled signal photon partner on the back screen (using a mechanism called coincidence counting). If the beam splitter is in place and the signal photons are later highlighted according to which detector the idler photon partner was detected at, then an interference pattern is revealed for each highlighted group (see Figure 2).

So does this imply a "backwards in time" effect, albeit hidden? No, the two interference patterns are always encoded in the total signal photon pattern and can even be used to predict the probability of measuring the idler photon at D1 or D2. For example, suppose a signal photon was detected at D0 at the location indicated by the green bar in Figure 2. Note that there is a peak for D1 and a trough for D2. This predicts that the idler photon will, with near

Figure 3: D0 = D1 + D2 (without the beam splitter)

certainty, be detected at D1. The correlation is due simply to the entanglement between the signal and idler photons which the measurement after the beam splitter verifies.

If the beam splitter were not present, then D1 and D2 would instead detect which slit the original photon passed through (i.e., the "which-way" information). So if the signal photons were highlighted according to which detector the idler photon partner was detected at, then a non-interference pattern would be revealed for each highlighted group (see Figure 3).

References:

A Delayed Choice Quantum Eraser - experiment by Kim et al., in 1999.

The Notorious Delayed-Choice Quantum Eraser - blog post by Sean Carroll

The delayed choice quantum eraser, debunked - blog post by Sabine Hossenfelder

Delayed Choice Quantum Eraser - slides by Anita Kulkarni

Delayed-choice quantum eraser - Wikipedia

Saturday, 27 November 2021

The diagonal lemma

Figure 1: Diagonalization (where a code for a function is
fed into the function itself)
The diagonal lemma (or fixed point theorem) is an essential part of several notable mathematical proofs including Gödel's incompleteness theorems and Tarski's undefinability theorem.

The term diagonal is used because it bears some resemblance to Cantor's famous diagonal argument.

Intuitively, the diagonal lemma says that for any property A, there is a self-referential statement B saying that it has property A.[1] The lemma is expressed as a logical equivalence:

\[\boldsymbol{B \Leftrightarrow A(\#B)}\]

A can be any property about numbers such as isPrime or isEven. This means that statement B must be translatable to a number, which is indicated by the # in the lemma above. The translation is achieved by Gödel-numbering which assigns a unique natural number to every possible statement.

A simple way to implement Gödel-numbering is by converting the statement to its ASCII representation. So the statement "isEven(2)" translates to the number 69734576656e283229 in hexadecimal (which can be translated with a text to hex converter). That number is also translatable back to the original statement again. Thus there is a one-to-one mapping between a statement and its Gödel number.

Figure 2: Substitution along the diagonal
We can also represent statements containing free variables. For example, the statement "isEven(x)" translates to the Gödel number 69734576656e287829.[2] Now consider the table in Figure 2 where the rows (j) represent the Gödel numbers of statements and the columns (k) represent the possible values for x (themselves natural numbers). We can define the function sub(j, k) to translate Gödel number j as a statement, then substitute number k in place of x and, finally, translate that statement to a Gödel number. For example, sub(69734576656e287829, 8) will translate Gödel number 69734576656e287829 as "isEven(x)" then substitute 8 for x, producing the evaluable statement "isEven(8)" and finally translate that statement to the Gödel number 69734576656e283829.

Since k can be any natural number, we can also substitute the Gödel number of the statement itself. That is, sub(69734576656e287829, 69734576656e287829) will translate Gödel number 69734576656e287829 as "isEven(x)" then substitute 69734576656e287829 for x, producing the evaluable statement "isEven(69734576656e287829)" and finally translate it to Gödel number 69734576656e2836393733343537363635366532383738323929. This particular kind of substitution (where j = k) is called diagonalization because it shows up on the diagonal (i.e., the blue squares) of the table in Figure 2. This self-referential process is key to what follows.

To simplify, the diagonalization can be defined by a function with one free variable x:

\[\boldsymbol{diag(x) = sub(x, x)}\]

I will now declare one further function, C(x), as logically equivalent to the property A applied to diag(x):

\[\boldsymbol{C(x) \Leftrightarrow A(diag(x))}\]

Function C will also have a Gödel number which I'll call m. So m is the Gödel number of the function C which, on input x, is logically equivalent to interpreting x as a function, running x on itself, and then running A on the result (partially illustrated by Figure 1). For example, suppose input x is the Gödel number of "isEven(x)" and A is the property isPrime, then we would have: [3]

\[\boldsymbol{C(\#''isEven(x)'') \Leftrightarrow ~''isPrime(diag(\#''isEven(x)''))''}\]

As noted earlier, # indicates the Gödel number of the subsequent statement. Now suppose that m (the Gödel number of function C) is itself the input to function C. This will result in:

\[\boldsymbol{C(m) \Leftrightarrow A(diag(m))}\]

The diag function interprets m as a function (i.e., C(x)) and substitutes m for x (i.e., C(m)). So:

\[\boldsymbol{C(m) \Leftrightarrow A(\#C(m))}\]

Now let B = C(m) and the result is the diagonal lemma:

\[\boldsymbol{B \Leftrightarrow A(\#B)}\]

When expanded out, B is A(diag(#"A(diag(x))")) which is logically equivalent to the right-hand-side of A(#'A(diag(#"A(diag(x))"))'). For example, suppose that A is the property isEven. Statement B is then 'isEven(diag(#"isEven(diag(x))"))'. That is, B says that the diagonalization of the inner statement is an even number. But the diagonalization of the inner statement just is B's Gödel number. So, in effect, B says of itself that its Gödel number is even. Further saying that the Gödel number of B is even is, therefore, logically equivalent to what B already says of itself.[4]

The diagonal lemma can also be used to construct the famous Gödel statement where A is the property of being unprovable. That is:

\[\boldsymbol{B \Leftrightarrow isNotProvable(\#B)}\]

If B is true, then B is, as it says, not provable. Whereas if B is false, then it is false that it is not provable. That is, it is provable. Thus either statement B is true and not provable, and so the system is incomplete. Or else statement B is false and provable, and so the system is inconsistent (since it can prove a false statement). That is Gödel's first incompleteness theorem.

The diagonal lemma can also be used to construct the liar sentence where A is the property of not being true. That is:

\[\boldsymbol{B \Leftrightarrow isFalse(\#B)}\]

If B is true, then B is false. Whereas if B is false, then B truthfully asserts that. Either way, the result is a contradiction. The conclusion of Tarski's undefinability theorem is that the truth predicate is not definable in the object language, so the liar sentence cannot be constructed.

Useful references:

--

[1] Strictly-speaking, that the numeric representation of statement B has property A. This is indicated by the # which translates from the statement to a natural number (termed its Gödel number).

[2] In this post, the term statement indicates both formulas with free variables (e.g., "IsEven(x)", where x can be any natural number) and formulas without free variables (e.g., "isEven(2)" or "isEven(3)" which are sentences that evaluate as true or false).

[3] The right-hand-side statement resolves to "isPrime(69734576656e2836393733343537363635366532383738323929)". You can use the hex to text converter to decode the Gödel number.

[4] To step through the final substitution in detail:

The inner statement says, "isEven(diag(x))", i.e., "the diagonalization of x is even". To diagonalize that statement is to substitute its Gödel number for x. That is:

    'isEven(diag(  #"isEven(diag(x))"  ))'

Which is to say, 'the diagonalization of #"the diagonalization of x is even" is even'. While the final statement just is the diagonalization of the inner statement, it also asserts a property of the diagonalization of the inner statement, namely, that it is even. Thus, in effect, the statement is asserting a property of its own Gödel number (that it is even).

Sunday, 16 August 2020

Visualizing general relativity

Figure 1: The equivalence between gravity and acceleration
This post is part of a series on visualizing relativity.

As noted in the previous post, the first postulate of special relativity states that the laws of motion are the same in all inertial reference frames.

An inertial frame has no external forces acting on it, so either remains at rest or moves at a constant speed along a straight path. It would seem, then, that special relativity is applicable to gravity-free space but not to Earth where objects in free fall accelerate due to gravity.

This brings us to Einstein's thought experiment. Suppose you are in a compartment where you release an apple and observe it fall to the floor (see Figure 1). This occurs for a compartment at rest on Earth, due to gravity. But the same motion of the apple would also be observed if you were out in space and the compartment were accelerating upward at a rate of 9.8 m/s. There is an equivalence between these two scenarios - the laws of motion with respect to the apple are the same in both reference frames.

Now suppose you are in a compartment where you release an apple and observe it stay in the same position. This would occur for a compartment in free fall on Earth. The compartment and all the objects in it would be accelerating at the same rate, due to gravity though, relative to you in the compartment, the apple would be motionless. But the same (lack of) motion of the apple would also occur if you were out in space and the compartment were at rest. Again, there is an equivalence between these two scenarios - the laws of motion with respect to the apple are the same in both reference frames.

This is Einstein's equivalence principle which motivates the general theory of relativity. The laws of motion are the same for the compartment in free fall whether on Earth or in space. If this is so then it would seem that the compartment in free fall on Earth is an inertial reference frame. But, if so, then there can be no external force acting on it. That is, rather than accelerating, it is either at rest or moving at a constant speed along a straight path.

But how can this be? The apple certainly appears to be accelerating. Einstein's answer was that spacetime itself is curved and the apple follows a straight path (geodesic) through curved spacetime. This is illustrated in Figure 2 below (from this animation). In the Newtonian diagram, the apple is initially hanging on a branch. An upward force (green) is holding the apple and gravity (red) is pushing it down. When the apple falls off the branch, gravity pushes it down to the ground. In the Einsteinian diagram, only an upward force (green) is holding the apple which results in a curved trajectory through spacetime. When the apple falls there are no longer any external forces acting on it, so it follows a straight path through spacetime. Indeed, an accelerometer in free fall will measure zero since there are no forces acting on it.

Figure 2: Newtonian gravity vs Einsteinian curved spacetime

So that's the basic idea behind general relativity. A free falling frame is locally equivalent to an inertial frame and a gravitational field is locally equivalent to an acceleration. [1] We perceive the falling apple as accelerating downward but it's really us that are being accelerated upward by the Earth (as an accelerometer shows) and the falling apple's reference frame is inertial.

Let's now return to Alice and Bob from the previous post on special relativity and see how spacetime curvature affects one's predicted measurements of time and space. The following Epstein diagrams have been generated from Adam Trepczynski's relativity app.

Figure 3: Alice after 1 second in her rest frame
Suppose Alice (in her rocket) is motionless in space, far enough away from any massive objects so that there are virtually no gravitational effects. That is, local spacetime is flat.

As shown in Figure 3, Alice has traveled 0 light seconds [2] in space and aged by 1 second.

The yellow coloring indicates her rocket which, with respect to her rest frame, is not rotated in spacetime and is not contracted in length.

The clocks at the bottom indicate the elapsed coordinate time of 1 second (cyan) and Alice's elapsed proper time, or aging, also of 1 second (purple).

Figure 4: Bob after 1 second in Alice's rest frame
Figure 4 shows Bob (and his rocket) as measured by Alice in her rest frame. In 1 second of her proper time, Bob has traveled 0.6 light seconds in space and aged by 0.8 seconds (Bob's proper time).

The yellow coloring indicates Bob's rocket which is rotated in spacetime and is contracted to 0.8 of its rest length as measured by Alice.

The clocks at the bottom indicate the elapsed coordinate time of 1 second (cyan) and Bob's elapsed proper time of 0.8 seconds (purple).

Figure 5: Alice is stationary (in curved spacetime)
So far, I have described what Alice and Bob measure in situations that are unaffected by gravity.

Now suppose that Alice and Bob are on a massive planet that curves spacetime (note: the planet is to the right along the space axis, with the proper time axis bending away from it). Alice is on a rocket launch pad on the top floor of a (very tall) tower, while Bob is on a floor 0.6 light seconds below.

Note that Alice and Bob are being accelerated upward by the planet and tower. Since Alice is stationary (with respect to her spatial position on the planet), she moves only through time, aging by 1 second, as shown in Figure 5.

This is analogous to the apple's motion through spacetime while it is still hanging on the tree branch.

Figure 6: Bob is stationary (in curved spacetime)
Figure 6 shows Bob on the lower floor (i.e., to the right of Alice on the space axis). He ages 0.63 seconds as measured by Alice who has aged by 1 second, and he remains 0.6 light seconds lower in altitude than her.

This is an example of gravitational time dilation. Bob ages less than Alice since he is closer to the gravitating planet. [3]

Figure 7: Alice in free fall (in curved spacetime)
Now Bob catches the elevator to meet up with Alice on the top floor. Alice, in her rocket, launches off the top of the tower. She is initially at rest (with respect to the planet) and in free fall. Figure 7 shows that after 1 second of coordinate time, Alice has traveled 0.41 light seconds in space (downward) and aged 0.79 seconds.

That effect is what we call gravity. While Alice traveled in a straight line at a constant rate, the curvature of spacetime changed her direction from purely through time to partly through space as well. [4]

A way to visualize the diagram in Figure 7 is as a three dimensional truncated cone. The cyan line will no longer appear straight, but will increasingly curve down the cone.

This is analogous to the apple in free fall increasing in speed over time (relative to the tree branch).

Figure 8: Bob in free fall (in curved spacetime)
In Figure 8 Bob, not to be left behind, launches off the top of the tower with an initial downward velocity of 0.6 times the speed of light and in free fall. After 1 second of coordinate time, Bob has traveled 0.79 light seconds in space (downward) and aged 0.46 seconds.

As with Alice, even though Bob is traveling in a straight line at a constant rate, the curvature of spacetime changes his direction to be proportionally more through space than time than if spacetime were flat. Which is to say, Bob ages less and moves further through space than in Figure 4.

So that's the geometry of spacetime according to general relativity.

To review, the special theory of relativity states that the laws of motion are the same in all inertial (non-accelerating) reference frames. But what about accelerating reference frames? Einstein's subsequent insight was that acceleration and gravity are equivalent. Suppose Alice is on a train and experiences a jerk forwards as the result of the train braking. She can interpret this as the deceleration of the train. Or, equivalently, she can interpret herself as being permanently at rest while the world around her moves under the influence of a gravitational field. [5] Gravity, in turn, can be understood as curvature in spacetime. Thus acceleration can be understood as curvature in spacetime.

The consequence is that while any frame can serve as a rest frame (thus generalizing special relativity), the presence of spacetime curvature means that other frames may only be inertial with respect to that rest frame when in its local neighborhood and for a limited time. Keeping that in mind, the following principle can be stated:

General principle of relativity: The laws of motion are the same in all reference frames

So with reference to the general theory of relativity, what does this mean for Alice? It means that her frame can always be interpreted as a rest frame. And any frame that is accelerating with respect to Alice can be explained by the curved geometry of spacetime. Those rules apply equally for Bob, or any arbitrary reference frame.

--

[1] The equivalence principle is a local equivalence - globally, gravity exhibits tidal effects. Consider also two free falling observers on opposite sides of the Earth. Both are in inertial frames yet, globally, they are accelerating towards each other. So measurements can only be compared locally where spacetime is approximately flat. Finally, consider that gravitation obeys the inverse square law and so will not be equivalent to uniform acceleration over large distances.

[2] 1 light second - the distance light travels in 1 second - is about 300,000 km (or 186,000 miles). The circumference of the Earth is about 40,000 km (or 25,000 miles), so light can travel around the Earth 7.5 times per second.

[3] For an analysis of the curvature of the time axis, see Gravitation and the Curvature of Space-Time. (See also Relativity Visualized, p145, and gravitational redshift.)

[4] Recall Epstein's myth from the previous post - Alice is moving at the speed of light through spacetime (as represented by coordinate time t). But as she progresses she is moving less in time and more in space, with the limit being the speed of light through space. That limit can't be reached in coordinate time t, but can be reached in a finite amount of proper time τ. (See also Relativity Visualized, p150.)

[5] My example is drawn from the following passage in Einstein's book, Relativity: The Special and General Theory:
'It is certainly true that the observer in the railway carriage experiences a jerk forwards as a result of the application of the brake, and that he recognises, in this the non-uniformity of motion (retardation) of the carriage. But he is compelled by nobody to refer this jerk to a "real" acceleration (retardation) of the carriage. He might also interpret his experience thus: " My body of reference (the carriage) remains permanently at rest. With reference to it, however, there exists (during the period of application of the brakes) a gravitational field which is directed forwards and which is variable with respect to time. Under the influence of this field, the embankment together with the earth moves non-uniformly in such a manner that their original velocity in the backwards direction is continuously reduced."'
Einstein's thought experiment is similar to Galileo's in the sense that visual cues in the environment are discounted. While the frames can't be differentiated experimentally, an observer would normally differentiate them based on those visual cues (i.e., that the ship is moving on the water and that the train is decelerating). On this view, the observer's alternative interpretation in Einstein's thought experiment introduces a pseudo-gravitational field and does not involve actual spacetime curvature. General relativity is then reserved for real gravitational fields (due to matter) that exhibit as curvature in spacetime.


Glossary


The equivalence principle: The local effects of motion in a curved spacetime (gravitation) are indistinguishable from those of an accelerated observer in flat spacetime.

A geodesic is a straightest-possible line in a surface or a more general space. In the plane, the geodesics are straight lines, on the surface of a sphere they are great circles.

Gravitational time dilation: clocks in the vicinity of a mass or other source of gravity run more slowly than clocks which are farther away.


Resources


Friday, 31 July 2020

Visualizing special relativity

The twin paradox
This post is part of a series on visualizing relativity.

As noted in the previous postspecial relativity is based on two postulates:

1. The laws of motion are the same in all inertial frames
2. The speed of light is the same in all inertial frames

The conventional view is that we live in a three-dimensional world where time proceeds at a constant rate for all of us independent of motion. But Einstein's theory shows that we instead live in a four-dimensional spacetime where space and time are interdependent. (Note: technical terms are explained in the Glossary at the end of this post.)

Lewis Carroll Epstein in his book Relativity Visualized presents a myth for intuitively understanding the special theory of relativity. As he puts it:
Why can't you travel faster than light? The reason you can't go faster than the speed of light is that you can't go slower. There is only one speed. Everything, including you, is always moving at the speed of light. How can you be moving if you are at rest in a chair? You are moving through time. (pp78-79)
So, according to the myth, each of us are always travelling at the speed of light through 4D spacetime. Since Alice is always at rest with respect to herself, that sets her time direction. The three directions perpendicular to her time direction are the space directions that she perceives. If Alice changes her velocity, she rotates in spacetime such that she is now at rest with a new time direction.

When Bob is travelling at close to the speed of light, Alice measures Bob as aging slowly (time dilation) and shortened in the direction of motion (length contraction). This is simply the effect of Bob being rotated in spacetime relative to her and then projected onto Alice's coordinate system. But in Bob's (at rest) reference frame, his wristwatch is running normally and his shape and size are normal. This is analogous to how a round table appears oval when viewed from an angle. However the difference with relativity is that the projection is not simply perceptual, but is the outcome of collecting measurements from local observers who use clocks and rulers.

Alice's measurements of Bob from her rest frame can be represented by an Epstein spacetime diagram [1] as shown in Figure 1 below.

Figure 1: Bob is travelling at 0.6 times the speed of light in space (relative to Alice)

Alice's proper time is on the vertical axis, while her space dimension is perpendicular to it on the horizontal axis (note: only the x-space dimension appears - the y-space and z-space dimensions are omitted). A radius represents 1 light year in a particular direction - vertical (for Alice at rest), horizontal (for a photon) or an intermediate direction (for Bob).

Alice travels 0 light years in space and 1 light year in time, i.e., she ages 1 year. At the other extreme, a photon travels 1 light year in space and 0 light years in time, relative to Alice.

According to Alice's measurements, Bob travels 0.6 light years in space. Bob's proper time can be calculated using the Pythagorean Theorem (where coordinate time is the length of the red arrow - Bob's worldline, Bob's proper time is the spacetime interval, and coordinate space is the distance Bob has traveled according to Alice's measurements): [1]

coordinate time2 = Bob's proper time2 + coordinate space2

Solving for Bob's proper time, where the coordinate time (the length of Bob's arrow) is 1:

Bob's proper time = √(coordinate time2 - coordinate space2)
                  = √(12 - 0.62)
                  = √(1 - 0.36)
                  = √(0.64)
                  = 0.8 years (or 9.6 months)


Since Bob has only traveled for 0.8 years at a velocity of 0.6c, the distance he has traveled in his rest frame is less than 0.6 light years. Bob's distance (according to his measurements) can be calculated using the usual distance formula:

Bob's proper space = velocity * Bob's proper time
                   = 0.6 * 0.8
                   = 0.48 light years


Figure 2: Alice is travelling at 0.6 times the speed of light in space (relative to Bob)

In Figure 2, the same situation is shown, but from Bob's (at rest) reference frame. This is achieved by rotating the coordinate system such that Bob's arrow is on the proper time axis. Note that it is now Alice that has aged 0.8 years relative to Bob's 1 year.

These results may seem contradictory - how could it be that Bob has aged less than Alice in Alice's reference frame, but Alice has aged less than Bob in Bob's reference frame? The reason is that the time measurement that each person does of the other is a projection onto their proper time axis. To demonstrate this geometrically, Alice and Bob's reference frames are superimposed in Figure 3. Each observer is at rest, but measures the other moving obliquely. The symmetry is similar to two boats drifting apart from each other, and each perceiving the other as smaller. However, as noted earlier, the difference with relativity is that the projection is measurable, not merely perceptual.

Figure 3: Alice and Bob's reference frames superimposed - the situation is symmetrical

If Alice and Bob meet up and compare notes, they will find no contradiction, i.e., they will be the same age, or just one will be younger than the other. To understand how this works, suppose that Bob returns to Alice at (very close to) the speed of light. His elapsed proper time will then be 0.8 years compared to Alice's now 1.6 years (since Alice ages a further 0.6 years during the return leg, while Bob does not age at all). Symmetrically, suppose that Alice returns to Bob at (very close to) the speed of light. Her elapsed proper time will then be 0.8 years compared to Bob's now 1.6 years. The opposite results in each case are due to the change in reference frames of the traveler (which is, in effect, an acceleration by the traveler that they themselves are able to detect).

These are instances of the famous twin paradox. An Epstein diagram can also show a more common rendering of the twin paradox, where Bob reverses course at the mid-point of his journey and returns to Alice at the same speed.

Figure 4: The twin paradox

In Figure 4, Bob travels the same total distance as in Figure 1, however this time he travels 0.3 light years on the outward journey and 0.3 light years on the return journey (in Alice's frame). As with the example above of Bob returning at the speed of light, Bob ages 0.8 years while Alice ages 1 year.

Figure 5: Alice measures the contracted length of Bob's rocket

In Figure 5, Alice and Bob are part of the way along their respective journeys (note: the solid blue and red arrows are the same length), with the lengths of their respective rockets shown (exaggerated to be visible). Since Bob is traveling relative to Alice, Alice measures Bob's rocket to be shorter than its proper length, as projected on her spatial axis. For example, suppose the proper length of Bob's rocket is 0.1 light years. To calculate the length contraction, Bob's rocket can be rotated a quarter anticlockwise turn to lie along Bob's proper time axis (the red arrow) and projected onto Alice's proper time axis. Since the rocket is 0.1 times the length of the unit line, its projection against the proper time axis is 0.1 * 0.8 = 0.08. Rotating back, its projection against the space axis is also 0.08 light years. [2]

Bob would similarly measure Alice's rocket to be shorter than its proper length. (To see this, rotate the coordinate system such that Bob's arrow is on the proper time axis - then project Alice's rocket onto the spatial axis.)

In summary, both the time dilation and length contraction of an observed entity can be understood as projections onto the observer's proper time and spatial axes respectively. An entity observed by Alice to be travelling very close to the speed of light would be measured as having almost no elapsed time on its clock and almost entirely length contracted.

--

[1] The most common spacetime diagram is the Minkowski diagram. However I've instead used the Epstein diagram here due to its intuitive representation (for a comparison, see Figure 6 below). An Epstein diagram is a space-proper-time diagram that shows the worldlines of objects traveling below the speed of light (i.e., on timelike, but not lightlike or spacelike paths). The basis for the Epstein diagram is explained below.

The Euclidean metric for calculating the total distance between points in 3 dimensional space is:

d2 = x2 + y2 + z2

This is just an application of the Pythagorean Theorem in a Euclidean space. Of interest here is that if a 1 meter ruler is rotated in space, the x, y and z coordinates can all change, but d will remain invariant.

The Minkowski metric for calculating the total "distance" (i.e., the spacetime interval L) between points in 3+1 dimensional spacetime is:

L2 = x2 + y2 + z2 - (ct)2
   = d2 - (ct)2


It can also be expressed with an imaginary term:

L2 = x2 + y2 + z2 + (ict)2
   = d2 + (ict)2


Or, as an alternative convention, the signs can be flipped (omitting the negative sign on L2):

L2 = (ct)2 - x2 - y2 - z2
   = (ct)2 - d2


Minkowski space is non-Euclidean. Of interest here is that if a 1 meter ruler is rotated in spacetime, the x, y, z and t coordinates can all change, but L will remain invariant. Note that when d increases, so does t.

Rearranging the equation:

(ct)2 = L2 + d2

Which looks just like the Pythagorean Theorem! The spacetime interval L is a measure of the observed object's proper time (τ), d is a measure of the traveled distance, c is the speed of light (normalized to 1 in this post) and t is the elapsed coordinate time. Thus:

t2 = τ2 + d2

That is the basis for the Epstein diagram. In essence, Minkowski diagrams represent a hyperbolic equation (τ2 = t2 - d2) that is the difference of squares, whereas Epstein diagrams represent a circular equation (t2 = τ2 + d2) that is the sum of squares.

Figure 6 compares the Epstein and Minkowski diagrams for the twin paradox.

Figure 6: Comparison of Epstein and Minkowski spacetime diagrams

Epstein diagrams are visually intuitive and quantitatively correct. For example, on the Epstein diagram, it is clear that Bob has aged less than Alice since his proper time is shown as less than Alice's proper time when they reunite. Also, the worldlines are the same length, representing the same elapsed coordinate time. Compare with the Minkowski diagram where Bob's shorter proper time is shown by a longer worldline than Alice's.

[2] The geometry is explained here. In particular, note the similar right-triangles indicated by the angle φ. These triangles can be rotated such that their hypotenuse lies along Bob's arrow, allowing the shorter side lengths to be projected onto Alice's axes.


Glossary


An inertial frame is a reference frame that is either at rest or moving at a constant velocity (i.e., not accelerating).

Proper time (or rest time) is the time τ as measured by a clock in a rest frame. On an Epstein diagram (see Figure 6), proper time is represented on the y-axis. On a Minkowski diagram, proper time is represented by the worldlines. While Bob's proper time is shorter than Alice's, it's shown as longer on a Minkowski diagram.

Proper space (proper length, space displacement, rest length, or rest space) is the distance d as measured using standard length rods in a rest frame. On both Epstein and Minkowski diagrams, the observer's proper space is represented on the x-axis.

Coordinate time (or observer's time) is the time t of a moving object measured by an observer at rest. Thus it is the same for all objects. On an Epstein diagram, coordinate time is represented by the worldlines (which are the same length on the diagram). On a Minkowski diagram, coordinate time is represented on the y-axis.

Coordinate space (or observer's length, coordinate length, or coordinate distance) is the distance d that a moving object travels as measured by an observer at rest. Thus it is the same for all objects. On both Epstein and Minkowski diagrams, coordinate space is represented on the x-axis.

Spacetime is a mathematical model that fuses the three dimensions of space and the one dimension of time into a single four-dimensional manifold.

The worldline of an object is the path that the object traces in spacetime.

The spacetime interval between two events is the length of the segment of the worldline connecting the two events. It is invariant, which means that everyone measures the same value.


Resources


Monday, 27 July 2020

Visualizing Galilean relativity

Figure 1: Galileo's ship
This post is part of a series on visualizing relativity.

In 1632, Galileo gave a famous example of a ship travelling at constant velocity, without rocking, on a smooth sea. His claim was that any observer below the deck would not be able to tell whether the ship was moving or stationary.


In Figure 1, an experimenter releases a ball which drops vertically between time t1 and time t2. Does this imply that the boat must be stationary in the water? No, because if the boat is moving at a constant velocity, the ball will also move with that constant velocity (in the boat's direction of movement) and land in the same place, relative to the boat. Thus the experimenter is unable to tell whether the boat is moving at a constant velocity or is stationary.

This result is captured in the following principle:

Galilean relativity: The laws of motion are the same in all inertial frames

An inertial frame is simply a reference frame that is either at rest or moving at a constant velocity (i.e., not accelerating).

Note, however, that from the reference frame of the water (as indicated by the fish at rest between time t1 and time t2), the ball will follow a curved (parabolic) path. That is a measurable relativistic effect (in the Galilean sense).

Figure 2: Adding velocities
In Figure 2, a train is travelling at 100km/h and Bob (on the train) shoots an arrow at 200km/h toward the target. At the same time, Alice (on the ground) also shoots an arrow at 200km/h toward the target.

According to Alice, the velocity of Bob's arrow is the velocity of the train plus the velocity of the arrow according to Bob. That is, Alice would measure the velocity of Bob's arrow to be 100km/h + 200km/h = 300km/h. Thus Bob's arrow would hit the target before hers, even though both arrows had the same velocity in their respective frames of reference.

Figure 3: Adding velocities (light)
In Figure 3, Bob fires a laser that emits photons travelling at the speed of light (c) toward the target. Alice fires her laser at the same time. Alice, it seems, would measure the velocity of Bob's light to be c + 100km/h, and Bob's laser light hitting the target before hers.

However that is not what happens! Instead, the light from both lasers hits the target at the same instant and Alice measures the velocity of Bob's light to be c, just as Bob does.

This surprising result lead Einstein to extend Galilean relativity to include the following postulate:

The Principle of Invariant Light Speed: The speed of light is the same in all inertial frames

Galilean relativity and the principle of invariant light speed together comprise Einstein's special theory of relativity. As you may know, this gave rise to a number of unexpected consequences, including relativity of simultaneity, time dilation, length contraction and a new equation for adding velocities.

The next post will explore those consequences and present a way to intuitively visualize special relativity.

Visualizing relativity

The principle of relativity
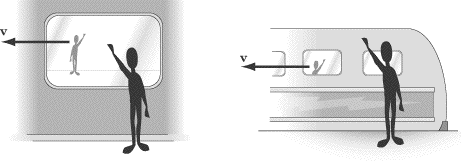
Suppose Alice is standing on a train platform waving her friend Bob goodbye as the train he is on moves away from the platform. From Alice's perspective, she is standing still on the platform while the train is moving away from her. But from Bob's perspective, he is standing still on the train while the platform is moving away from him.

We suppose that Alice and Bob are describing the same situation, as governed by the same laws of nature, but just from a different vantage point. This idea is captured by the principle of relativity:

Principle of relativity: The laws of nature are the same in every frame of reference

In the train example, Alice and Bob each represent a frame of reference. Those reference frames are relative to each other, hence the name of the principle. And the train scenario is governed by natural laws that are invariant across those reference frames.

This series of posts will show various applications of this principle and how to visualize their effects: